VL53L1X Time Of Flight Distance Sensor
The vl53l1x sensor platform allows you to use VL53L1X optical time of flight
(datasheet,
ST) sensors with ESPHome
to measure distances. The sensor works optically by emitting short infrared pulses
and measuring the time it takes the light to be reflected back.
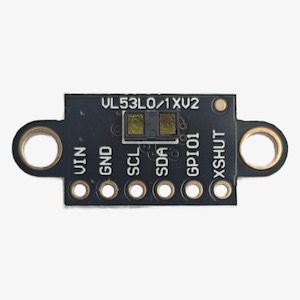
The VL53L1X is the successor to the VL53L0X with a longer range. It has three distance modes:
- Short mode: up to about 1.3m, with better immunity to ambient light
- Medium mode: up to about 3m
- Long mode: up to about 4m in the dark (default)
Range depends on how well the target reflects light, on ambient light, and on the sensor settings. The component follows the register sequence of ST’s VL53L1X Ultra Lite Driver (ULD), so short and long mode and their timing budgets are the ones that driver supports. Medium mode uses ST’s standard ranging register values.
The I²C Bus is required to be set up in your configuration for this sensor to work.
# Example configuration entrysensor: - platform: vl53l1x name: "VL53L1X Distance"The sensor reports the distance in meters. When a measurement fails or the sensor reports an invalid
range, the state is set to NaN.
Wiring
Section titled “Wiring”VCCconnects to 3.3VGNDconnects to groundSCLconnects to I²C SCL (clock)SDAconnects to I²C SDA (data)GPIO1is the interrupt output and is not used by ESPHomeXSHUTconnects to a free GPIO pin and is used asenable_pin. It is optional for a single sensor at the default0x29address, and required for every sensor when more than one VL53L1X shares an I²C bus.
Configuration Variables
Section titled “Configuration Variables”-
distance_mode (Optional, string): The distance mode, one of
short,mediumorlong. See Distance Modes. Defaults tolong. -
timing_budget (Optional, Time): The time allowed for a single distance measurement. A longer budget gives more accurate readings at a lower measurement rate. Must be one of
15ms,20ms,33ms,50ms,100ms,200msor500msin short mode, and one of20ms,33ms,50ms,100ms,200msor500msin medium and long mode. Defaults to50ms. -
signal_rate_limit (Optional, float): The minimum return signal rate in MCPS (mega counts per second) needed for a valid reading. Must be greater than 0 and less than 512. A lower value may increase the range but also the chance of inaccurate readings. Defaults to
1.0. -
roi_width (Optional, int): Width of the Region of Interest (ROI) in SPADs, from 4 to 16. Defaults to
16(full field of view). -
roi_height (Optional, int): Height of the Region of Interest (ROI) in SPADs, from 4 to 16. Defaults to
16(full field of view). -
roi_center (Optional, int): The SPAD at the center of the ROI, from 1 to 255. If not set, a ROI of 10x10 or smaller is centered on the calibrated optical center of the sensor, and a larger ROI uses
199. When the ROI is wider or taller than 10, this must be199. -
offset (Optional, int): Calibration offset in millimeters, from -1024 to 1023. Defaults to
0. -
address (Optional, int): The I²C address of the sensor. Defaults to
0x29. If another address is set, the sensor is re-addressed at startup, which requiresenable_pin. When more than one VL53L1X shares an I²C bus, every sensor must be set to an address other than0x29. -
enable_pin (Optional, Pin Schema): The pin connected to XSHUT on the VL53L1X. Required when
addressis not0x29, and for every sensor when more than one VL53L1X shares an I²C bus. -
update_interval (Optional, Time): The interval to check the sensor. Defaults to
1s. -
All other options from Sensor.
Distance Modes
Section titled “Distance Modes”The distance modes trade maximum range against immunity to ambient light.
Short mode is best for:
- Bright environments or outdoor use
- Targets closer than about 1.3m
- Fast measurements, since it allows a
15mstiming budget
Long mode (default) is best for:
- Targets up to about 4m away
- Indoor use or low ambient light
Medium mode sits between the two, with a range of about 3m.
# Short range mode for faster readings in bright conditionssensor: - platform: vl53l1x name: "Short Range Sensor" distance_mode: short timing_budget: 20ms update_interval: 100msRegion of Interest (ROI)
Section titled “Region of Interest (ROI)”The VL53L1X has a 16x16 SPAD (Single Photon Avalanche Diode) array. By default all SPADs are used, giving a field of view of about 27°. A smaller ROI narrows the field of view, which is useful to:
- Detect smaller objects
- Reduce interference from nearby objects
- Create a more focused detection zone
# Narrow field of view configurationsensor: - platform: vl53l1x name: "Narrow FOV Sensor" roi_width: 8 roi_height: 8The minimum ROI size is 4x4 SPADs. Leave roi_center unset to use the optical center of the sensor.
Multiple Sensors
Section titled “Multiple Sensors”Multiple VL53L1X sensors can share one I²C bus. All sensors start at the same default address (0x29),
so each one is held in reset with its XSHUT pin while the others are given new addresses:
- Connect the XSHUT pin of each sensor to a different GPIO and set it as
enable_pin - Give each sensor its own
addressother than0x29
ESPHome rejects a configuration where a sensor on a shared bus has no enable_pin, stays at 0x29,
or uses the same address as another VL53L1X on that bus.
# Multiple VL53L1X sensors on the same I²C bussensor:  - platform: vl53l1x    name: "Distance Front"    address: 0x30    enable_pin: GPIOXX    update_interval: 500ms
  - platform: vl53l1x    name: "Distance Rear"    address: 0x31    enable_pin: GPIOXX    update_interval: 500ms
Calibration
Section titled “Calibration”The offset option compensates for a constant measurement error. To calibrate:
- Place a target at a known distance (for example 100mm)
- Read the measured value and convert it to millimeters (the sensor reports meters)
- Calculate offset = actual distance - measured distance, in millimeters
- Set
offsetto this value
# Calibrated sensor with a -5mm offsetsensor: - platform: vl53l1x name: "Calibrated Distance" offset: -5